Uncertainty has a geometry.
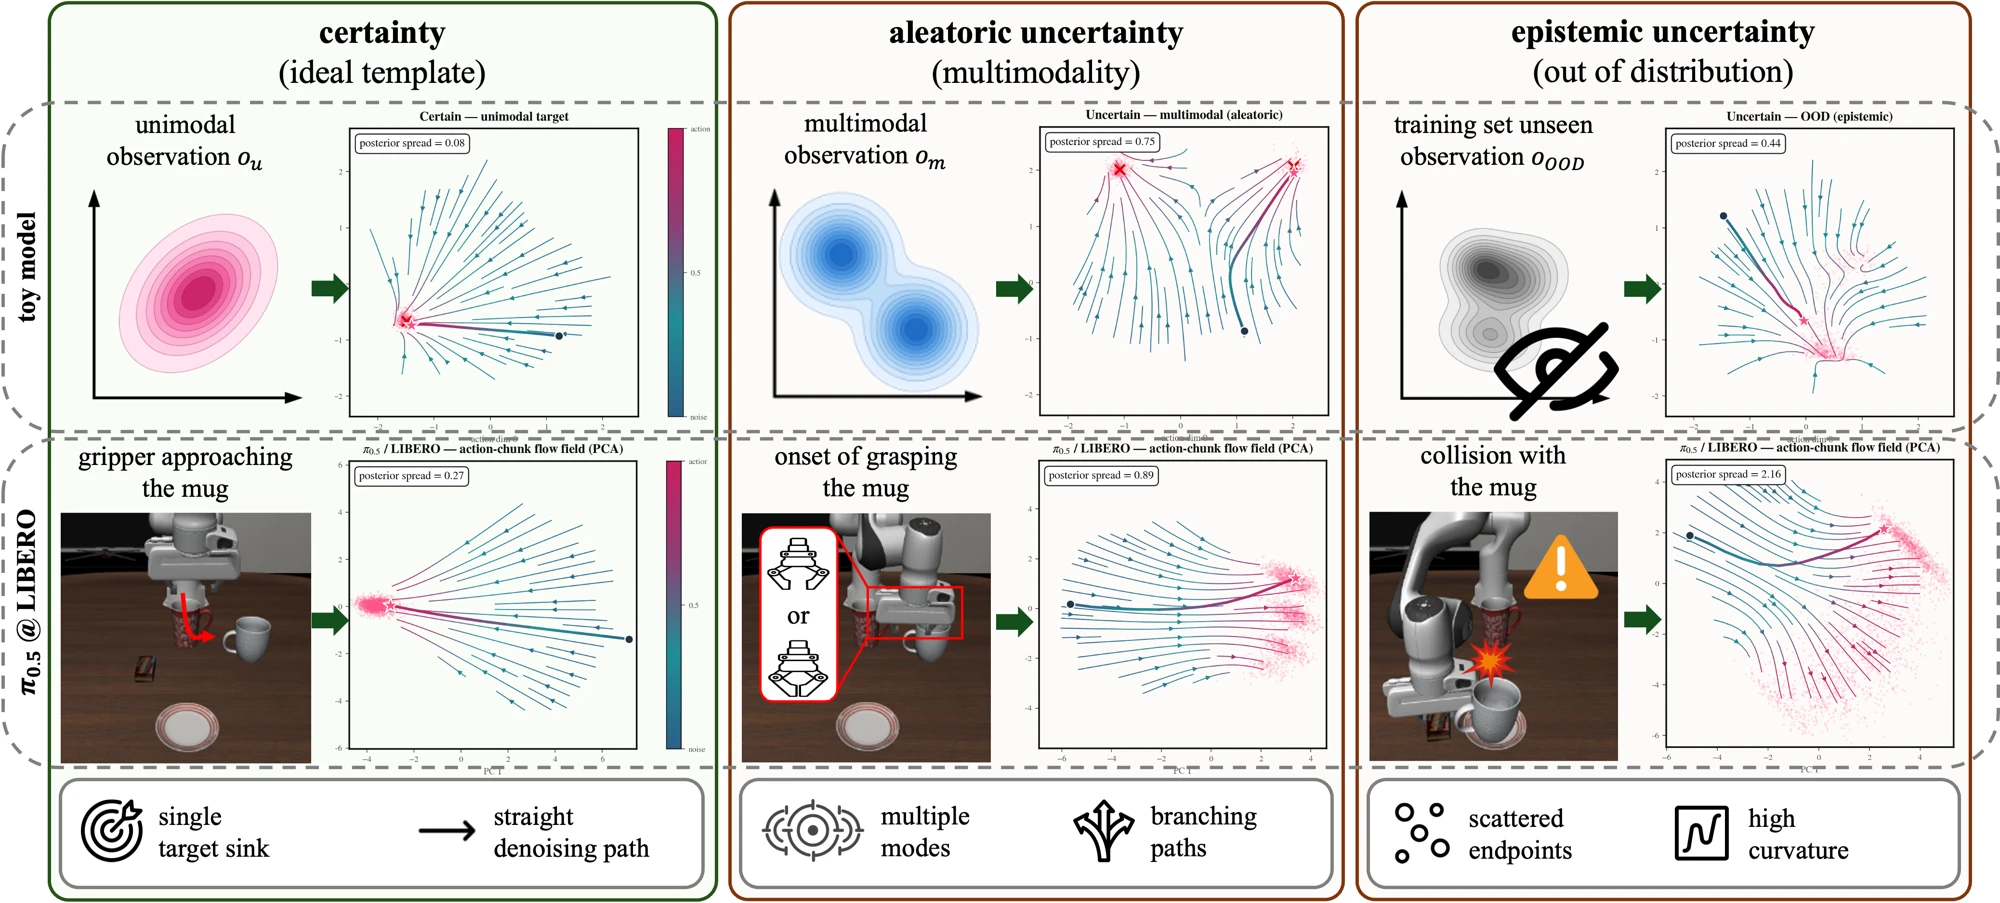
A certain flow contracts toward a single target. Multimodality and out-of-distribution inputs deform this ideal field and change the denoising path.
A Cost-free Uncertainty Proxy and Application in Flow-based VLA Failure Detection
* Corresponding author
There is a goal, but no way; what we call the way is hesitation.
Estimate flow matching uncertainty with denoising acceleration from the trajectory your policy already computes. A cost-free signal for online failure detection in vision-language-action (VLA) models, without extra model evaluations, training, or resampling.
Explore the geometry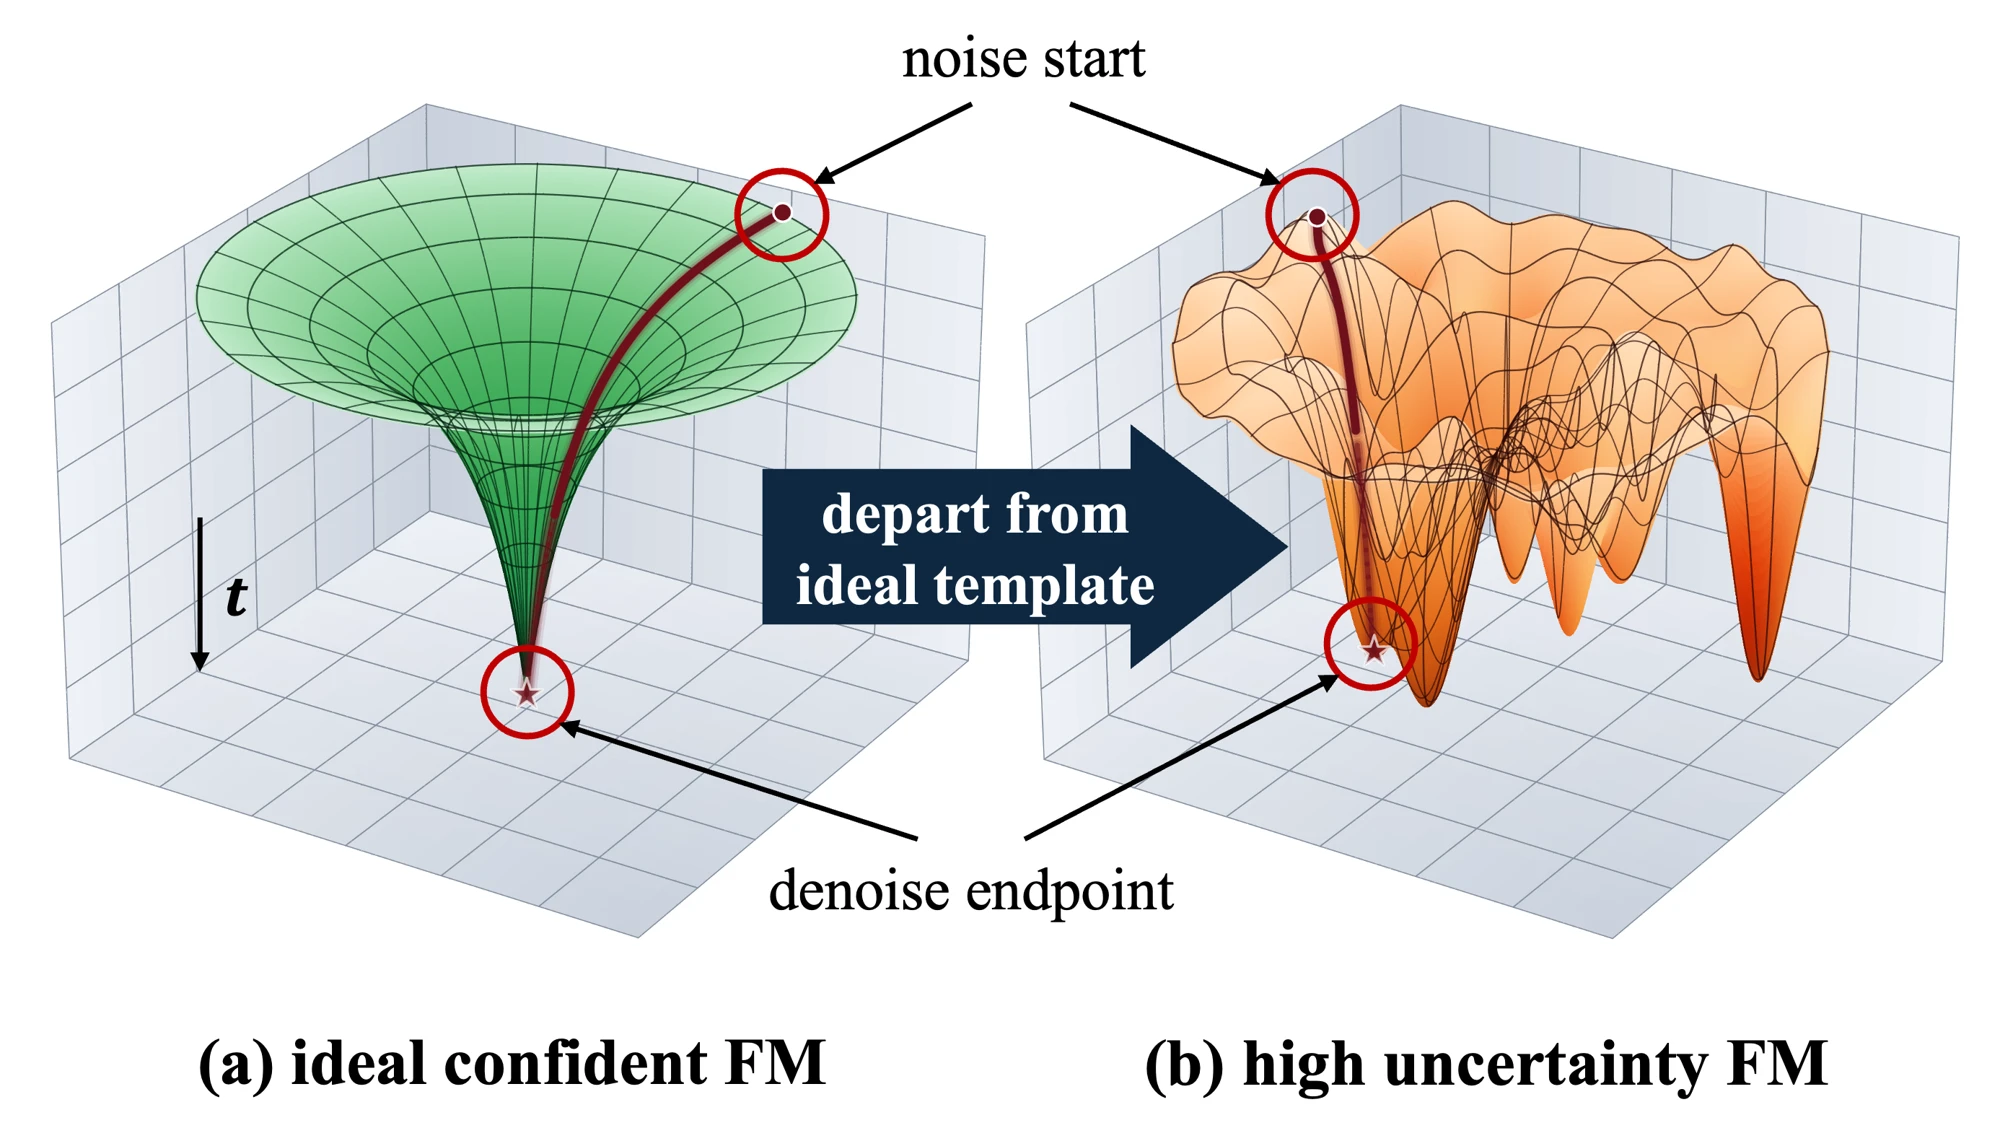
A certain flow contracts toward a single target. Multimodality and out-of-distribution inputs deform this ideal field and change the denoising path.
Denoising acceleration reads velocity variation from the trajectory the policy already computes. No extra model calls, resampling, or proxy training.
Combine accel with a calibrated CUSUM monitor to flag failing rollouts before termination, across different flow-based VLA architectures.
From simulation to a physical arm: the trajectory supplies the score, and CUSUM tracks sustained deviations.
The geometric score rises and CUSUM crosses the threshold at chunk 5 of 7, with 2 chunks (4.8 s) of lead.
The score decays as the task progresses. CUSUM remains below the threshold throughout the rollout.
Grounded in flow geometry. Validated against resampled uncertainty. A single denoising path supplies both the signal and the evidence.
Velocity variation, normalized by mean speed. Here p is the denoising prefix length. The proxy requires no training; the failure detector’s threshold is calibrated on successful rollouts.
Grounded in flow geometry and validated against resampled uncertainty.
Path acceleration tracks changes in the posterior mean the denoiser is chasing, connecting a single trajectory to posterior covariance. The paper establishes two properties that make accel a faithful uncertainty proxy.
For an ideal certain field, the target is fixed and denoising velocity is constant. Every prefix has exactly zero accel, including under Euler discretization.
For a fixed covariance shape Σ₀ with Σ = σ²Σ₀, the expected prefix score grows with posterior variance to leading order, with κ(τ) > 0. Greater uncertainty therefore produces a larger expected accel.
The guarantee is local and in expectation: it assumes an exact CFM field, small posterior spread with fixed covariance shape, and a prefix away from the clean-action endpoint. It is not a pointwise or universal ranking guarantee. Theory and proofs ↗
One trajectory tracks the uncertainty measured by resampling.
Across all 12 model × benchmark settings, accel positively correlates with the uncertainty measured by repeated action sampling. Best-prefix correlations range from 0.586 to 0.844, demonstrating that the free geometric signal consistently tracks posterior spread across architectures and tasks.
Table 1 · Pooled chunk-level correlation with resampled action divergence. Best prefix is the highest correlation over evaluated prefix lengths, not a separately held-out prefix choice. The 12 settings include four VLA architectures and a toy FM model.
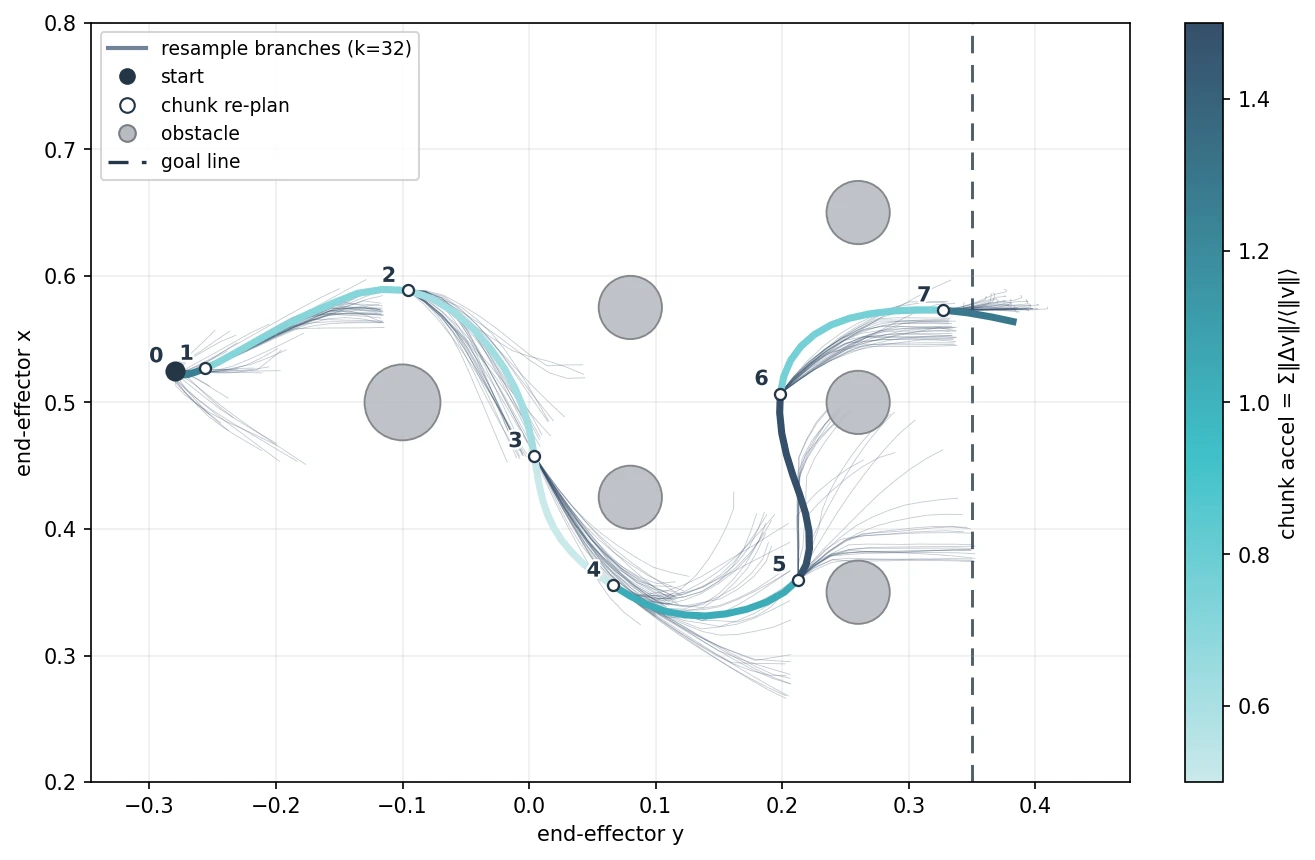
On D3IL, darker trajectory segments have higher accel. At those decision points, resampled action chunks fan out more widely, linking the single-path signal to posterior spread.
Evaluated on four flow-based VLAs across LIBERO-all and RoboCasa Atomic-Seen.
Accel approaches the strongest average baseline without training a probe or resampling actions. All detectors use the same calibrated CUSUM monitor.
| Detector | π₀.₅ | SmolVLA | GR00T-N1.7 | VLA-JEPA | Reported avg. |
|---|---|---|---|---|---|
| AccelGeometry · ours | 0.85 | 0.87 | 0.53 | 0.82 | 0.66 |
| StraightnessGeometry · ours | 0.78 | 0.87 | 0.58 | 0.64 | 0.65 |
| ACEResampling | 0.85 | 0.64 | 0.68 | 0.66 | 0.55 |
| STACResampling | 0.90 | 0.77 | 0.62 | 0.85 | 0.60 |
| Diff-DAggerResampling | 0.67 | 0.65 | 0.51 | 0.86 | 0.52 |
| FIPERTraining + resampling | 0.81 | 0.59 | 0.67 | 0.73 | 0.55 |
| RND-OETraining | 0.38 | 0.31 | 0.63 | 0.53 | 0.40 |
| LogpZOTraining | 0.38 | 0.31 | 0.65 | 0.46 | 0.41 |
| SAFETraining | 0.80 | 0.65 | 0.70 | 0.82 | 0.68 |
Table 2, arXiv v3. Resampling budget K = 32; training budget 32 rollouts (SAFE: 16 successful + 16 failed); calibration uses 50 held-out successes. The last column reproduces the paper’s reported average across all eight model × benchmark settings. GR00T-N1.7 is undertrained on LIBERO-all. See the paper for standard deviations and detection leads.
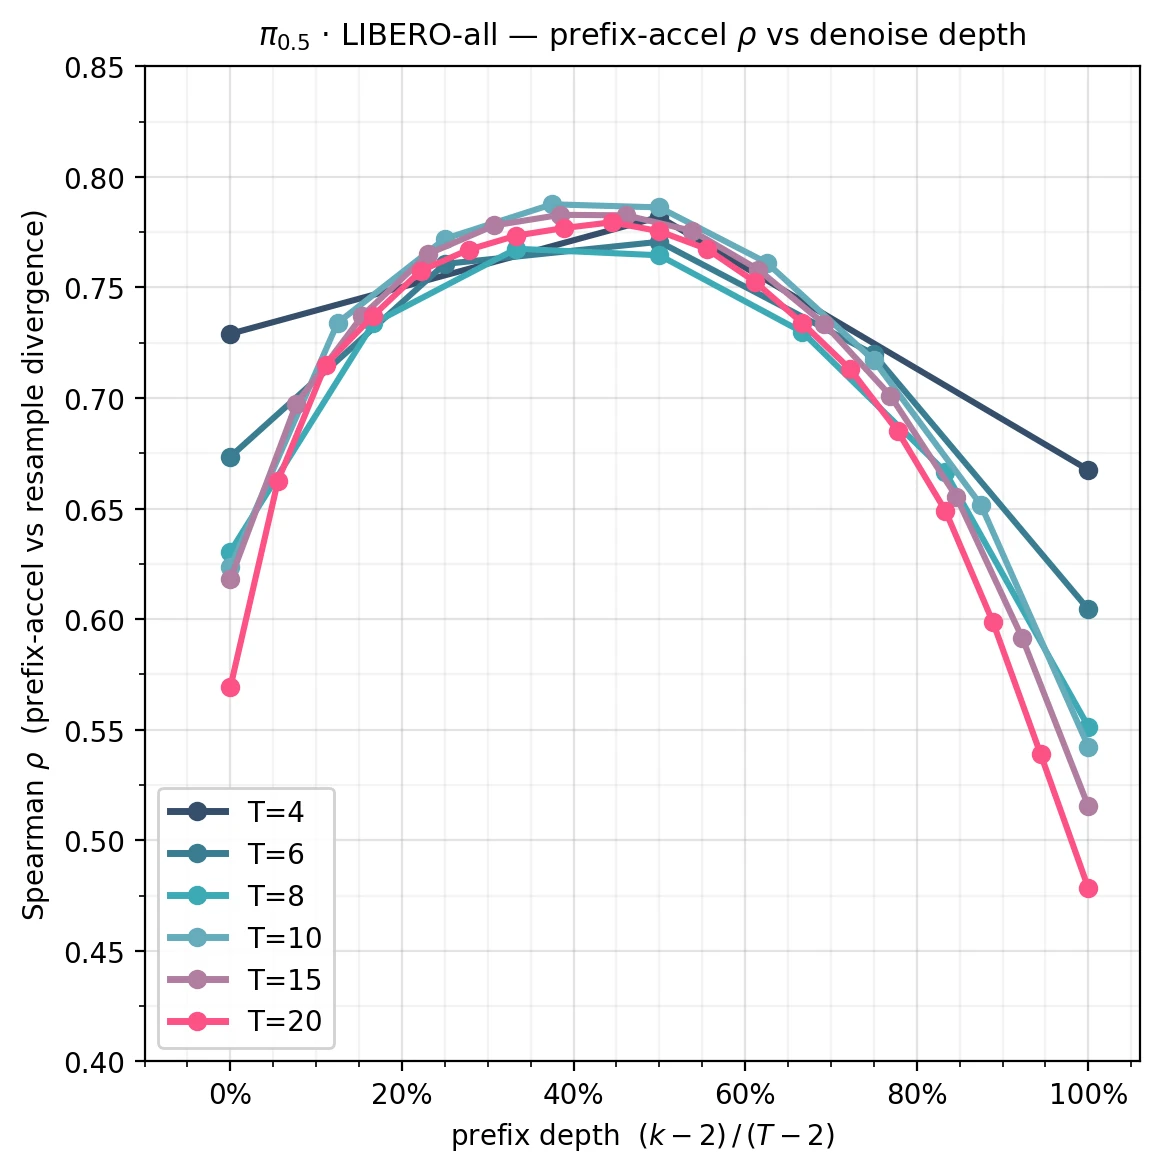
Truncating the end of the denoising trajectory often improves the correlation between accel and resampled action spread. The detector uses the second-to-last prefix over the executed action window.
Read the analysisAccel can miss a confidently wrong action, such as a misinterpreted instruction, or precision errors whose geometric changes are too small to distinguish from noise. It reads uncertainty in the FM head, not every possible cause of task failure.
Explore the implementation, reproduce the experiments, or cite the paper.
Preprint title: The Geometry of Flow-Matching Uncertainty: A Cost-free Uncertainty Proxy and Its Application in Flow-based VLA Failure Detection. arXiv:2607.27933.
@article{rao2026geometry,
  title={The Geometry of Flow-Matching Uncertainty: A Cost-free
         Uncertainty Proxy and Its Application in Flow-based VLA
         Failure Detection},
  author={Rao, Ziyang and Zhao, Yiren and Guo, Weiyu and
          Fei, Ben and Guo, Yandong and Xiong, Hui},
  journal={arXiv preprint arXiv:2607.27933},
  year={2026},
  url={https://arxiv.org/abs/2607.27933}
}